
Sensor Fusion in Robotics: Four Problems We Tend to Underestimate
September 23, 2026
Mobile robotics has driven a revolution, automating tasks across industrial, agricultural, and home environments. The list of use cases keeps growing every day.
To perceive and understand their surroundings, robots commonly carry multiple sensors of different types. Cameras, inertial measurement units (IMUs), GPS antennas, and LiDARs are among the most widely used. Fusing information from multiple devices enables much more robust localization and navigation. Even better, captured images allow the system to reason about the environment and make decisions, thanks to the evolution of AI methods.
Having multiple sensors is fundamental, and greater robustness is essential. However, there are problems inherent to using more than one sensor. Some are hard to detect and can remain latent. Below are a few of the problems that most roboticists run into at some point in their careers.
#1 Time Synchronization
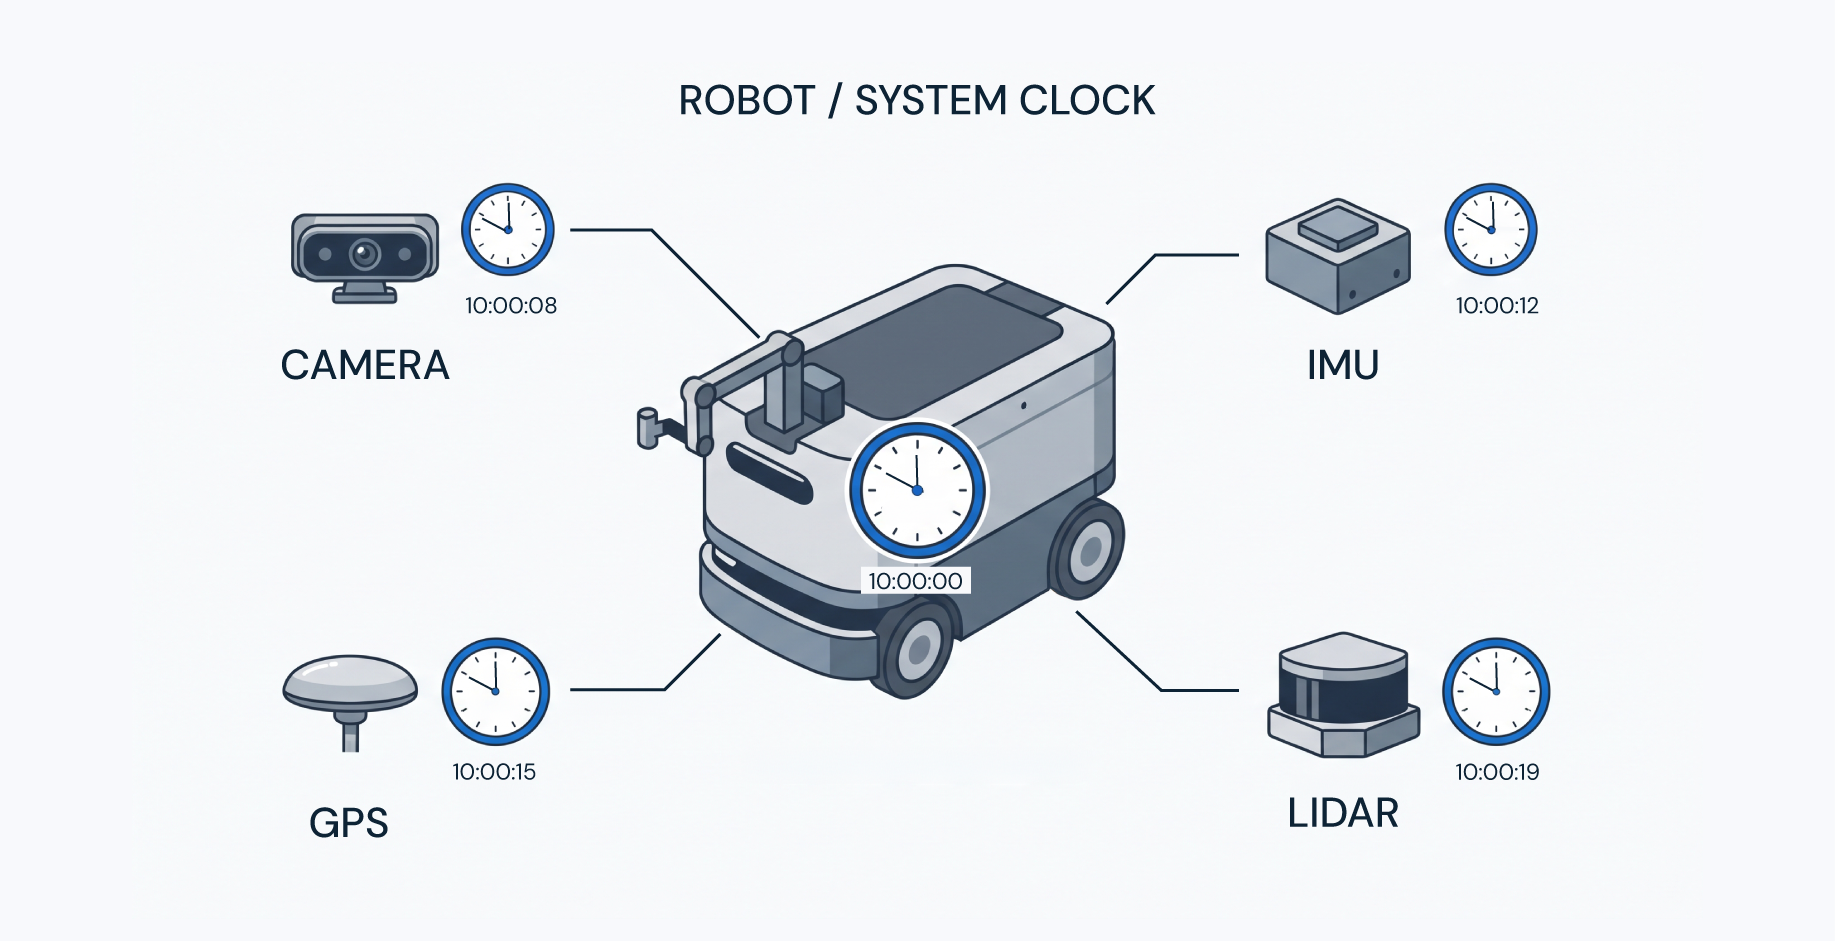
In general, a localization system fuses measurements from different sensors to estimate the position and orientation of a robot. Measurements come with the timestamp of the moment they were generated and, typically, each sensor has its own clock. However, many localization systems assume that measurements from different sensors share the same clock origin, which is usually not true in reality. To deal with this issue, some systems try to estimate the offset between clocks as part of the optimization problem.. This can be acceptable with just a camera and an IMU, but as more sensors are added to the stack, the complexity grows.
A few existing approaches address this:
- NTP (Network Time Protocol): network-based, millisecond-level accuracy; fine for keeping onboard computers' system clocks aligned, generally not precise enough for high-rate sensor fusion
- PTP (Precision Time Protocol): sub-microsecond accuracy with hardware timestamping
- GPS/GNSS-disciplined clocks (PPS - Pulse Per Second)
#2 Coordinate Frames
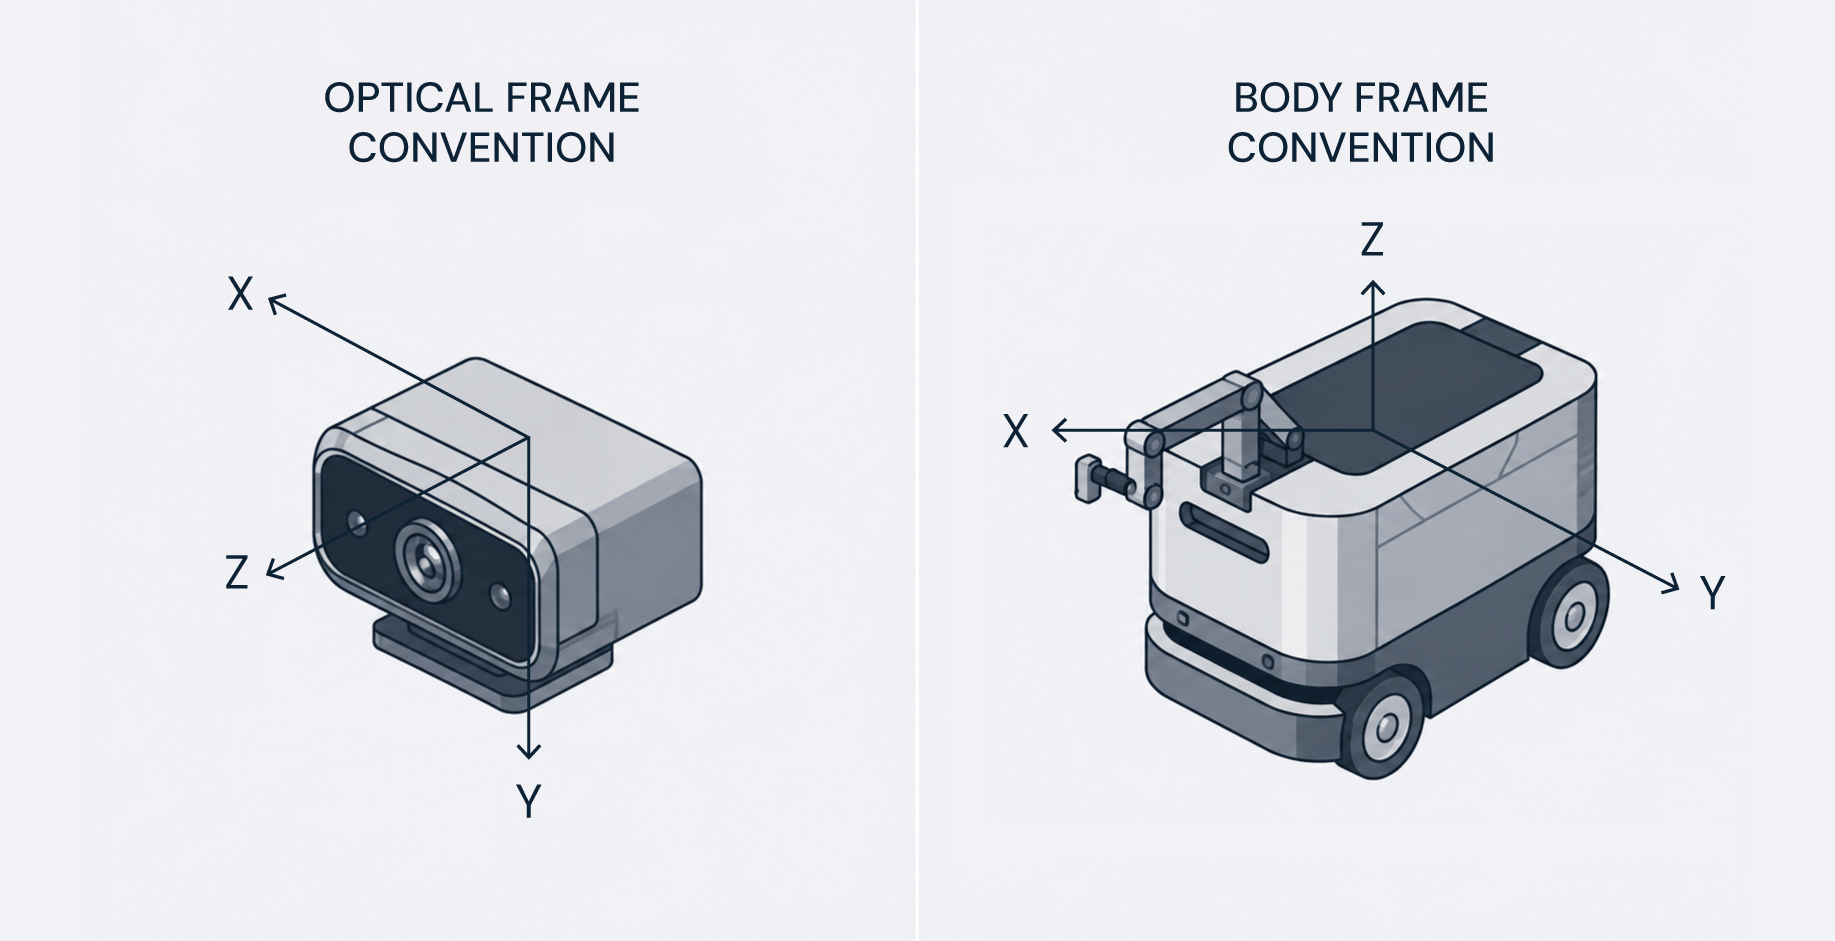
Just as timestamps are tied to a clock, sensor measurements are tied to a coordinate frame. It's important to identify which coordinate frames are involved in your system and how they relate to each other. Since state estimation and sensor fusion continuously transform measurements between these frames, an error in a transformation between coordinate frames produces a bug that's hard to detect, and it can manifest in unexpected ways, such as inconsistent trajectories, distorted maps, or apparently unreliable sensor measurements.
Furthermore, coordinate conventions themselves vary by frame and by application, and that's where subtle bugs can hide: for instance, ROS uses X-right, Y-down, Z-forward for camera optical frames, while its standard body-frame convention (base_link) uses X-forward, Y-left, Z-up. A mismatch between these conventions rarely crashes anything; it just quietly biases the estimate..
#3 Sensor calibration drift
Sensor calibration is the process of determining the parameters that describe how a sensor's measurements relate to physical reality. This includes intrinsic parameters (e.g., a camera's focal length and lens distortion) and extrinsic parameters (the sensor's exact position and orientation relative to the robot's base frame or another sensor).
Once a calibration is obtained, it's often assumed to remain fixed forever. In reality, it can change due to:
- Mechanical changes: vibration, shocks, a sensor mount moving slightly.
- Temperature: IMU bias, scale factors, and axis misalignment can vary substantially with temperature.
- Mechanical/thermal deformation.
Research has been carried out to mitigate this problem. For example, it's possible to monitor a calibration to determine when it needs to be recomputed.
#4 Recovery after failures
This is a gap we see often between academia and industry: open-source SLAM systems are usually designed for the "happy path." Many are overfit to perform accurately on a given dataset, and datasets generally fail to capture all the challenges of the real world. That's why these systems can lose tracking once mounted on a real robot and lack the ability to recover from failures. There is room to improve them and make them more robust: state machines to explicitly model tracking states (initializing, tracking, lost, relocalizing) and watchdog patterns that monitor tracking confidence, feature count, or reprojection error in real time and trigger fallback behaviors before the system silently crashes.
Conclusions
Most of these problems have something in common: they are silent failures. They don’t throw an obvious error, instead, they quietly degrade accuracy until the consequences show up downstream. That makes them hard to debug.
Closing the gap between a research prototype and a reliable product has become one of the main challenges nowadays. Robustness should be treated as a design goal in its own right and not as a side effect of a good algorithm.
If you're working through similar failure modes on your own robotics stack, we'd be glad to compare notes.
Stay focused on what’s next
Stories, ideas, and insights from the world of technology, product development, and innovation.


© Copyright 2026 Focus. All Rights Reserved.